Autonomy
Command software and an onboard autonomy kit for uncrewed vessels and ground vehicles. Canadian-owned and compatible with standard ArduPilot autopilots.

Command software and an onboard autonomy kit for uncrewed vessels and ground vehicles. Canadian-owned and compatible with standard ArduPilot autopilots.
In use
Command several vehicles from one station.
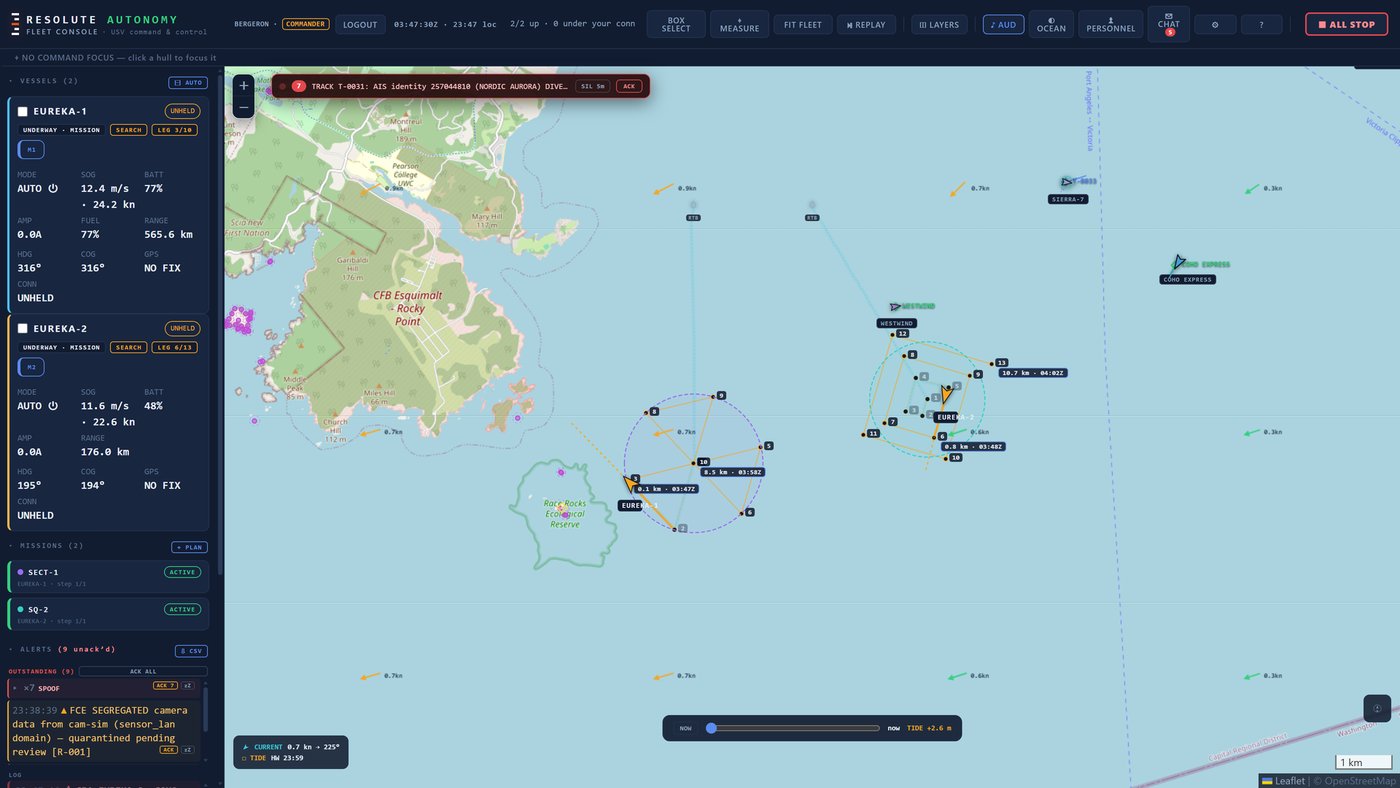
In use
Pilot a single vehicle remotely.
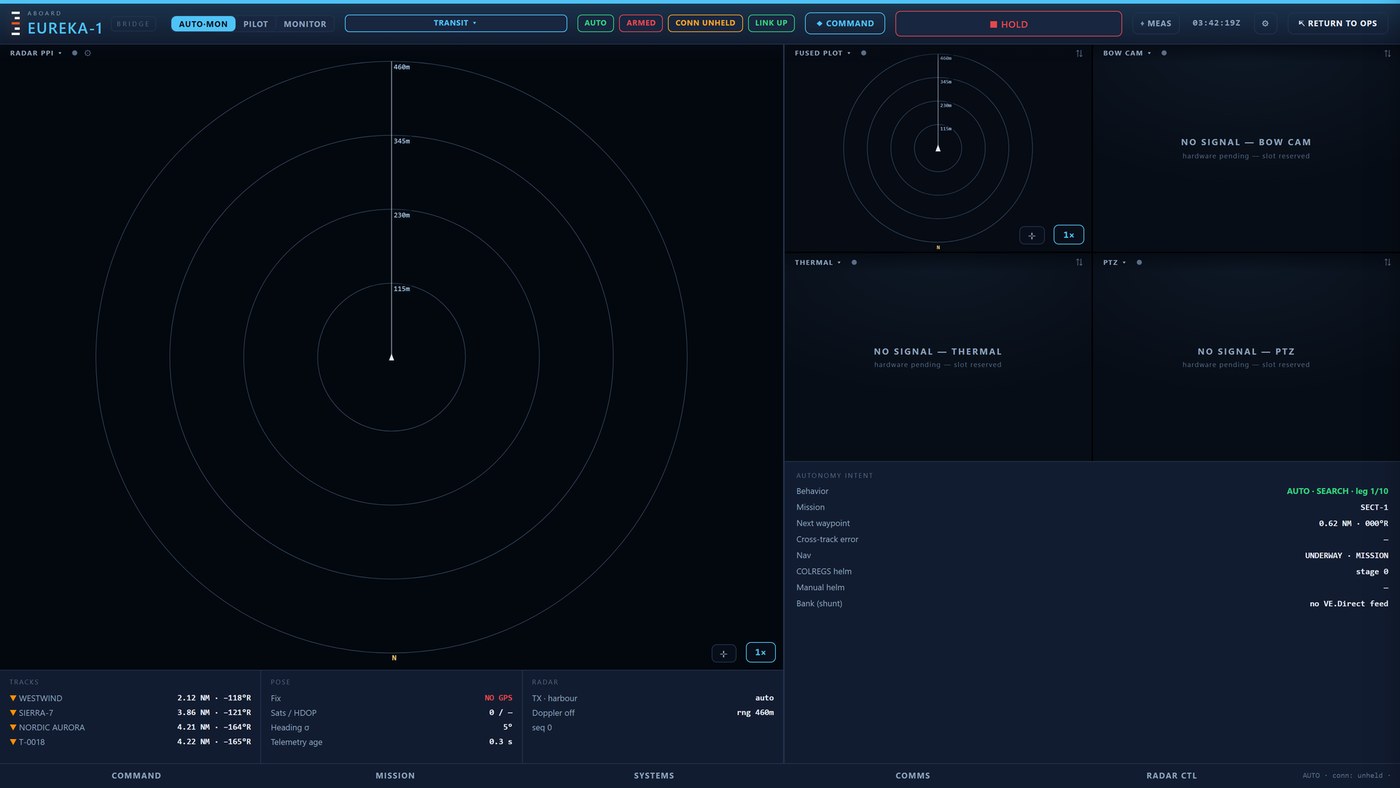
In development
Our autonomy kit includes everything a platform needs for autonomous and remote-controlled operation: autopilot, machine vision system, compute, vehicle health monitoring, control, and triple-redundant communication links.
In development
A portable station running the Fleet Console and the Bridge, for one vehicle or many.
A unified sensor compliance framework for multi-modal sensing with varying levels of sensor classification and data sensitivity.
Commands go over several links at once, so the vehicle stays connected if one link drops. If all links are lost, the vehicle follows a set procedure: it continues its current leg for a set time, then loiters and returns.
A multi-vehicle simulator for testing missions and software before they go to a vehicle.
| ArduPilot autopilots | MAVLink 2. |
|---|---|
| TAK | Cursor-on-Target position reports to a TAK Server, for ATAK, WinTAK and iTAK. |
| AIS | Live AIS traffic from network feeds, fused with radar contacts. |
| Electronic charts | IHO S-57 ENC cells, including CHS and NOAA charts. |
| Mission areas | GeoJSON and KML import. |
| Records | CSV export of tracks, events and reports. |
| Power systems | Victron systems over Modbus TCP. |