Platforms
Uncrewed vessels and ground vehicles, designed and built in Canada.

Uncrewed vessels and ground vehicles, designed and built in Canada.
Prototype in commissioning trials
A 16-foot uncrewed surface vessel that transits on gas and holds station on electric power and solar.
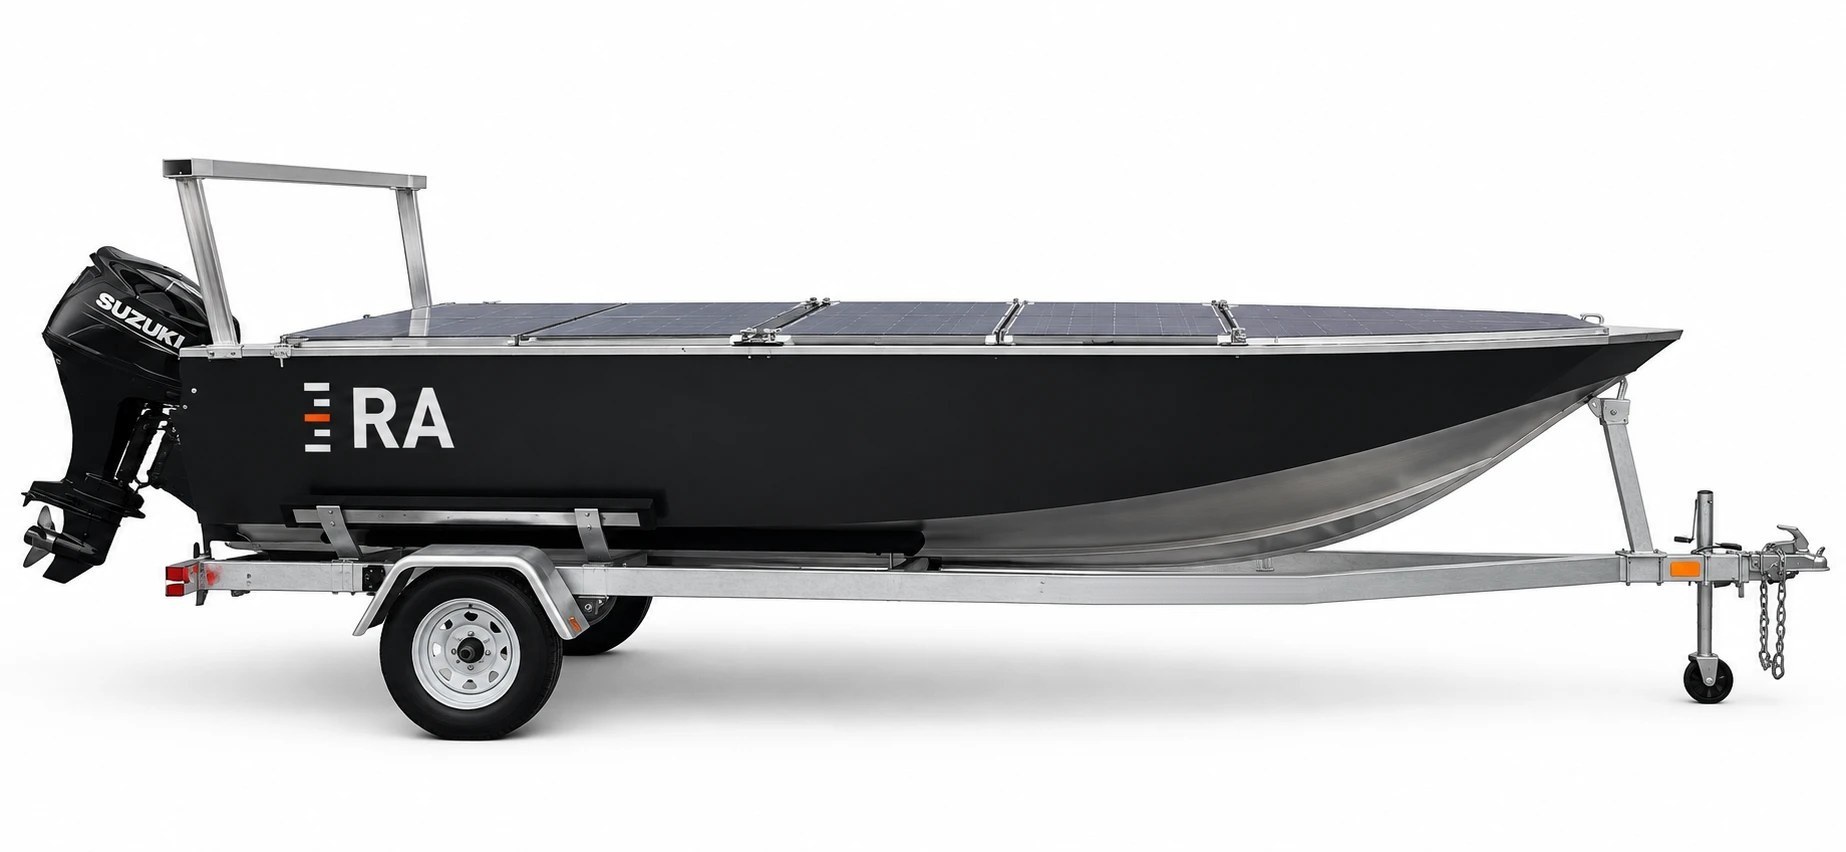
| Origin | Made in Canada by a Canadian-owned company |
| Length overall | 4.88 m (16 ft) |
| Beam | 1.73 m (68 in) |
| Draft | 0.15 m (6 in) with drives raised |
| Dry weight | 454 kg (1,000 lb) |
| Hull | Welded aluminum, 3.2 mm (1/8 in) plate, from a Canadian boatbuilder |
| Propulsion | Gasoline outboard for transit; differential electric thrusters for station-keeping and quiet manoeuvring |
| Fuel | 246 L (65 US gal) gasoline |
| Energy | 11 kWh lithium iron phosphate bank, self-heating for charging below freezing |
| Charging | 800 W solar on station; 19 A engine alternator underway; 50 A shore charger |
| Speed | 24 kt cruise, 30 kt maximum † |
| Range | Up to 1,200 km (648 nm) on gas at economical speed; 200 km (108 nm) on battery, extended by solar charging † |
| Endurance | Up to 60 days at sea † |
| Payload | 363 kg (800 lb) † |
| Sea state | Sea State 3 operating; Sea State 4 transit † |
| Sensors | Doppler radar, thermal camera, colour camera, AIS transceiver, dual-antenna multi-band GNSS |
| Navigation | Dual-antenna multi-band GNSS: RTK precision, true heading without a magnetic compass, and Galileo OSNMA authentication of the satellite navigation message |
| Compute | Onboard AI edge processor running our perception and navigation software |
| Communications | Starlink, LTE, and encrypted long-range radio; a set lost-link procedure if all links drop |
| Command | Operated from our fleet console; a single operator can command several hulls |
| Launch & recovery | Trailer launch from any boat ramp; two vessels stack in a standard 20-foot ISO container |
† Dimensions, construction, and fit are as built on the operating prototype. Performance figures are design targets being verified in on-water trials.
Download the Eureka class datasheet (PDF)Standard search patterns (parallel track, creeping line, expanding square, sector) planned from a drift-corrected datum. Several vessels can share one area.
Harbours, coastlines and chokepoints. Radar, AIS and camera contacts are fused into single tracks, and a contact whose AIS identity does not match its track is flagged.
Repeatable patrols of approaches, channels and boundary waters. A 6-inch draft reaches shallow water.
Closed-area boundaries, estuaries and river channels, with quiet station-keeping and thermal recording at night.
Speed in restricted zones, discharges, and vessels running without AIS, recorded with an audit trail.
Planned survey lines or long station-keeping for hydrographic and environmental payloads.
Reservoirs, pit lakes and remote lakes where a crewed boat would have to be trucked in.
Placing, checking and recovering drifters, sensor buoys and light moorings.
Payload and sensor fit are configured per mission.
In design
A smaller electric class for rivers, lakes and harbours, with an onboard diesel generator for long, quiet work.
In design
An uncrewed landing craft that carries ground vehicles and palletized cargo.
In development
A ground vehicle running the same autonomy kit as our vessels.
Concept drawings, preliminary. Configurations will change as the designs mature.